
AlexAsplund / Vanchor
Turn a cheap trolling motor into a smart GPS autopilot - virtual anchor, routes, cruise and drift modes from your phone. Runs offline on a Raspberry Pi, with ML-assisted station keeping that outholds a classic PID.
Why this job: works in the areas we cover, but does not say which job it does
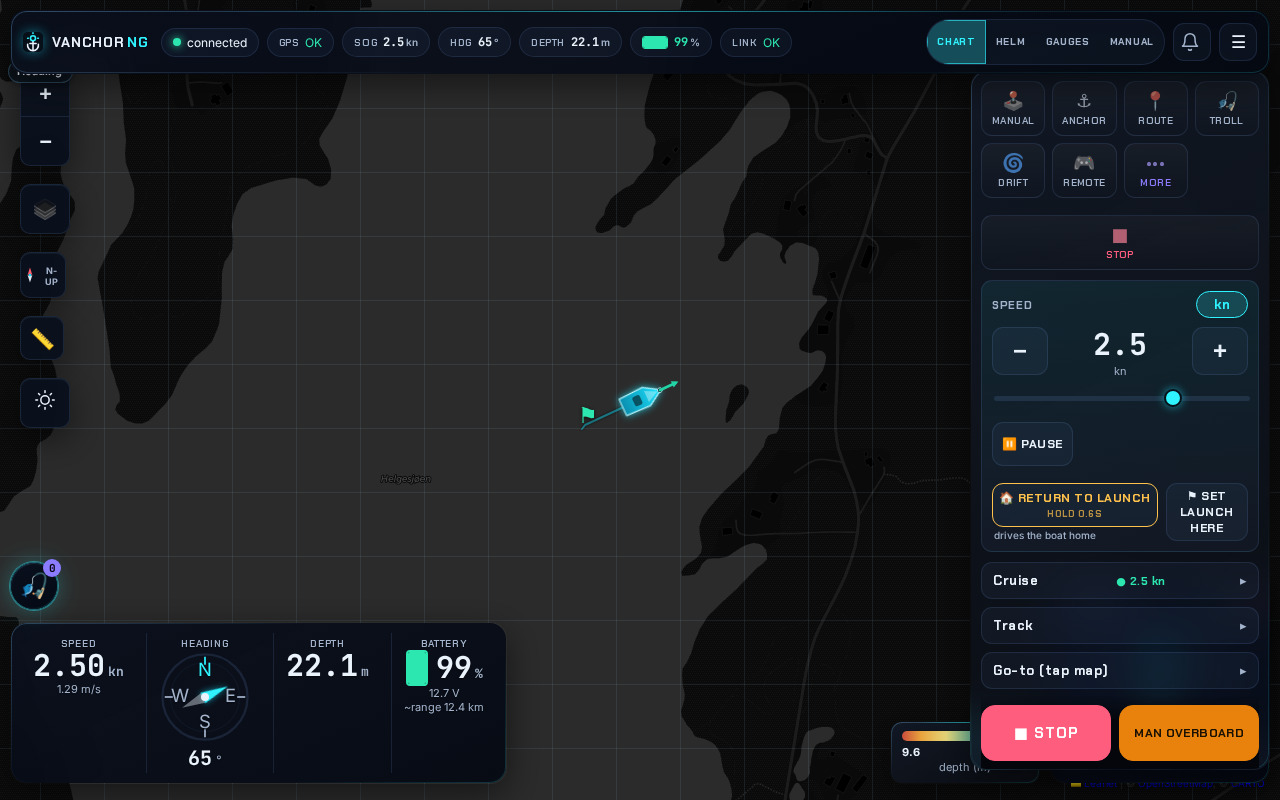
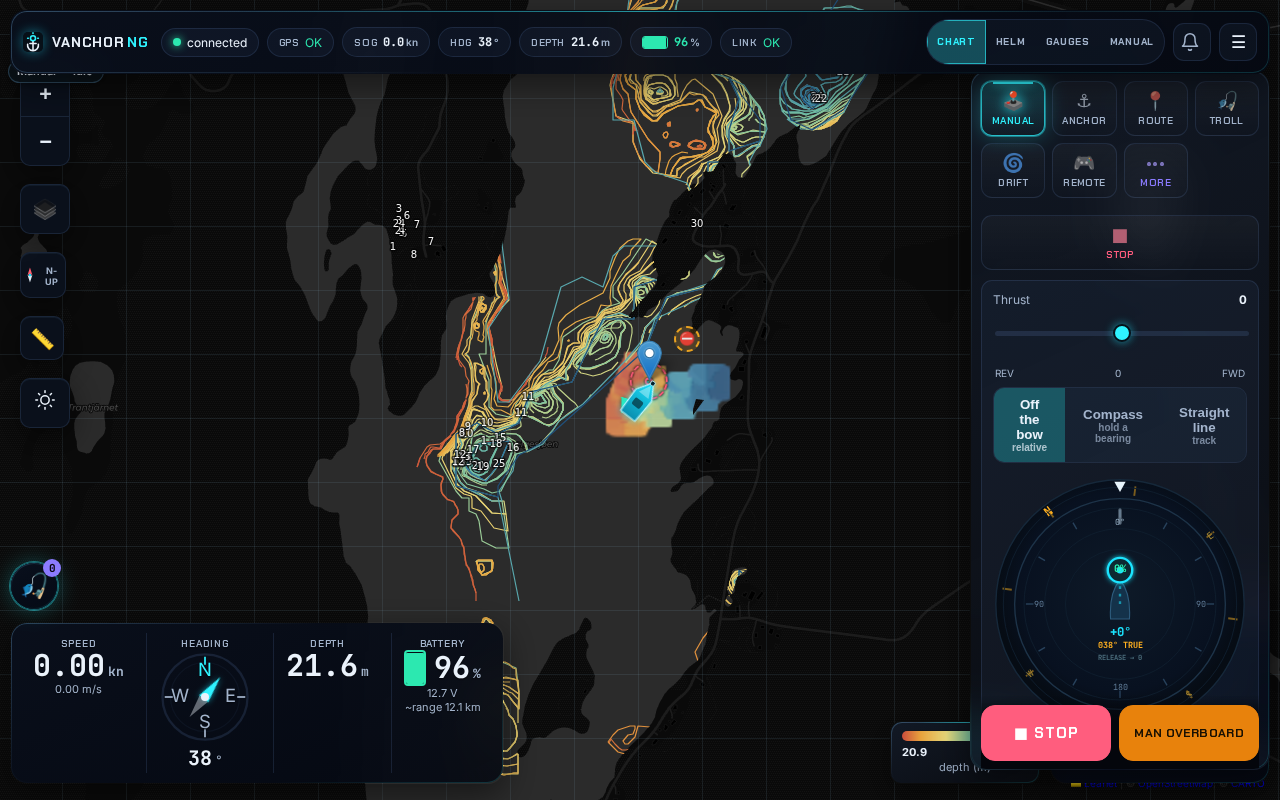
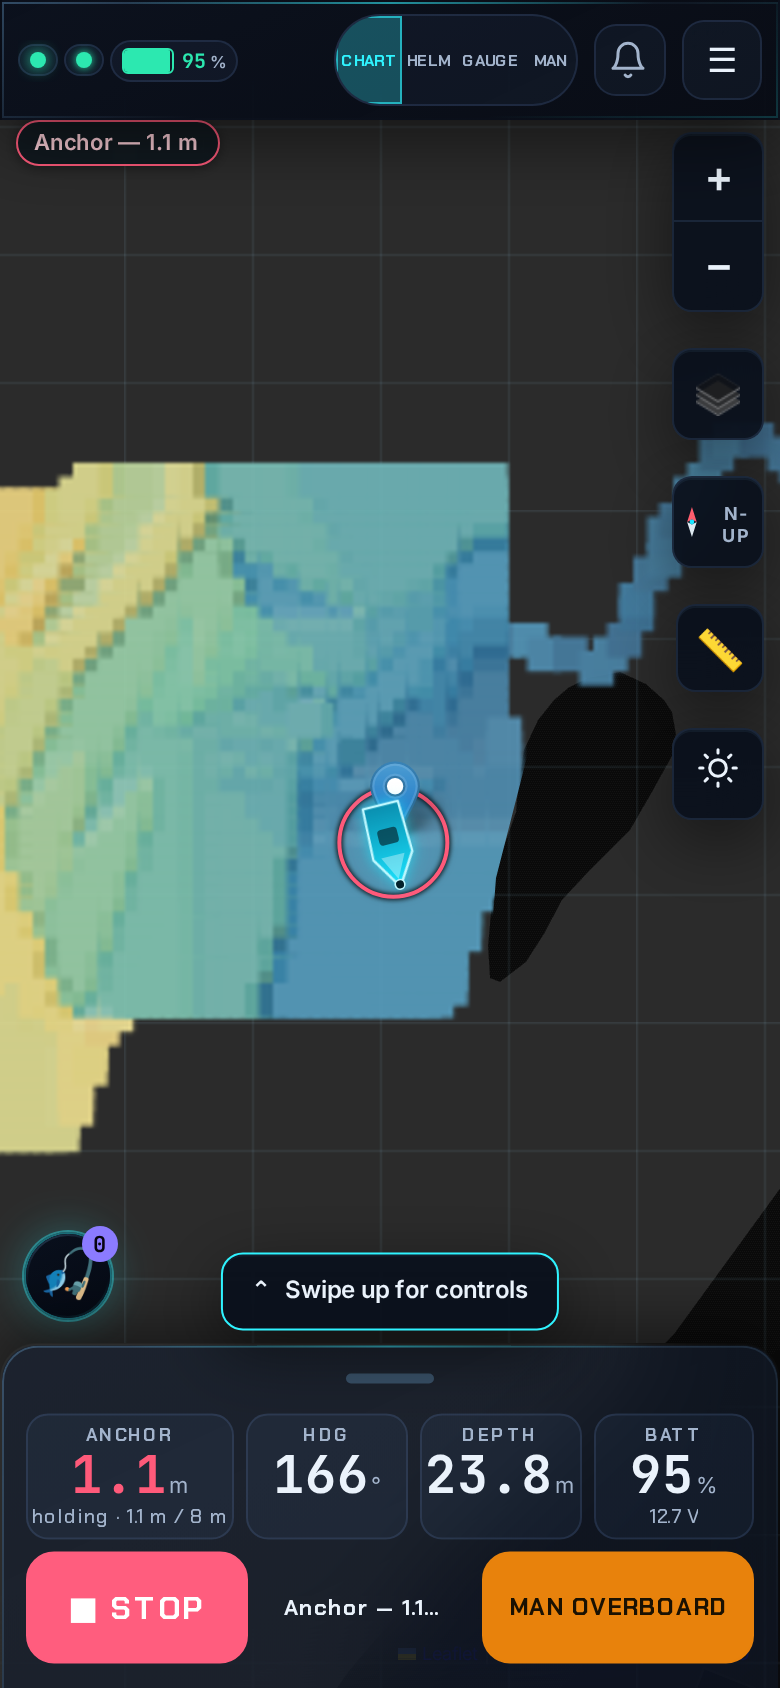
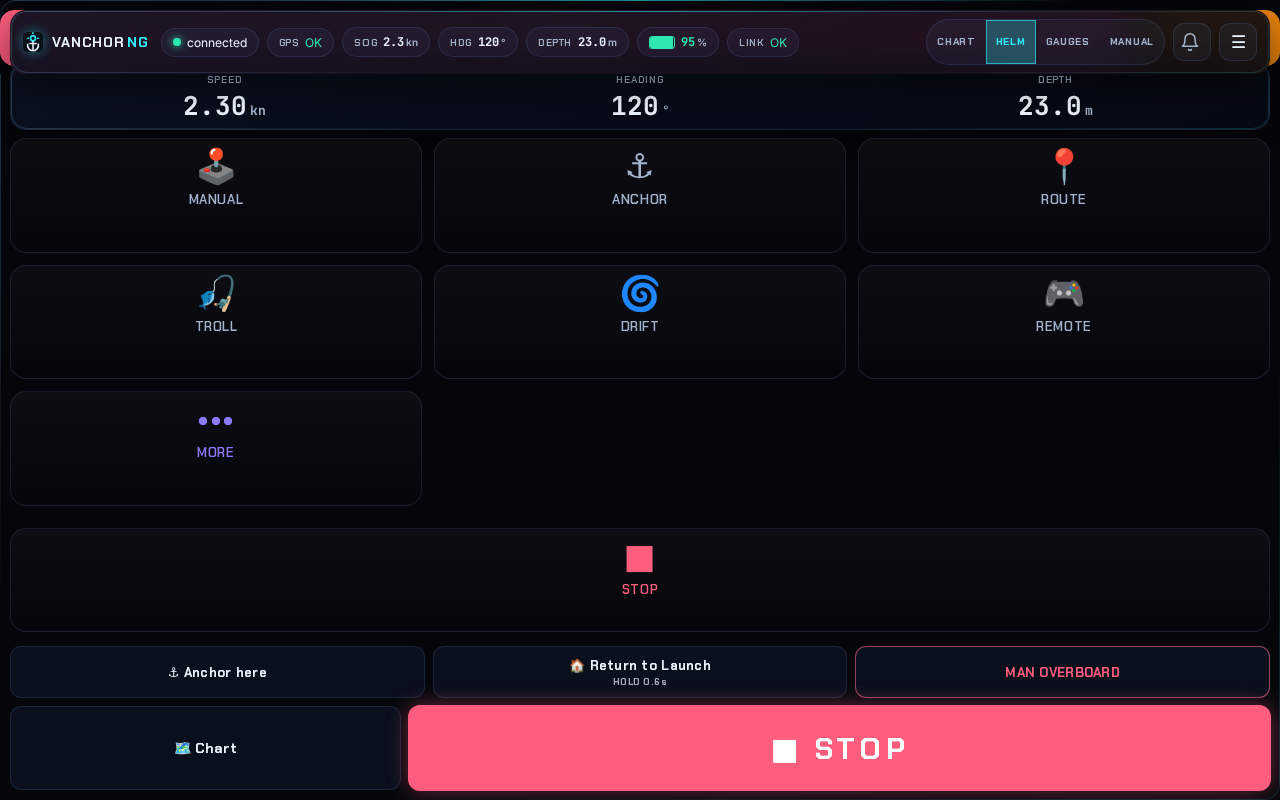
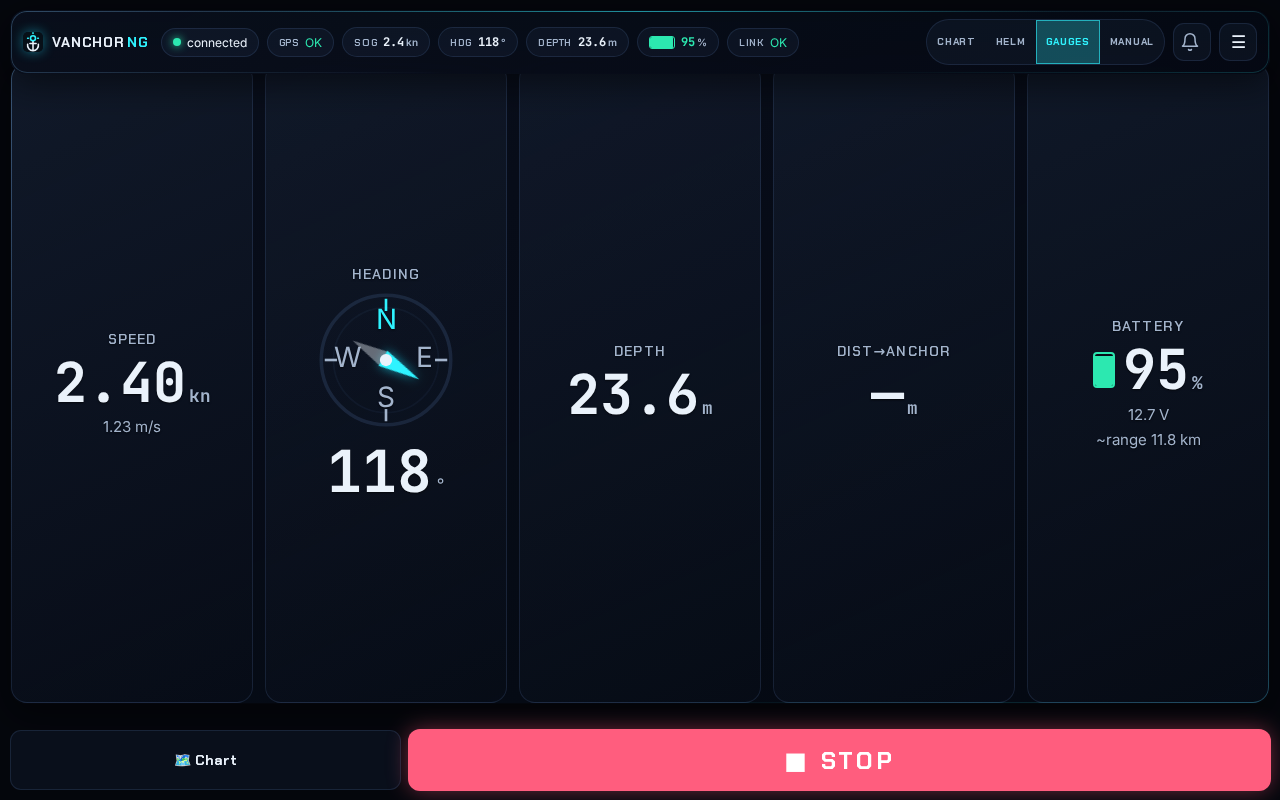
What it does
- Virtual GPS anchoring (position hold). drop a virtual anchor and hold the spot,
- Autopilot heading-hold. set a compass heading and hold it.
- Waypoint navigation with cross-track correction and predictive drift
- Smart "take me here" water routing. water-only routes that avoid land and
- Loop-around-island routing and area-survey "map mode" (lawnmower
Get started
No single install command. Read the steps in the README (opens in new tab)
- Maintenance
- Active
- Last commit 2 months ago
- Stars
- 126
- +1 this week
- Licence
- MIT
- Allows business use
- Downloads for
- None listed
- No release files
- Latest version
- v0.1-alpha
- Released 4 months ago
- Built with
- Python
- 72% of the code
Is it looked after?
- Contributors
- 1
- Last 90 days
- Issues
- 46% closed
- 47 still open
- Pull requests
- 74 merged
- 0 waiting
- Releases
- 34
- 30+ in the last year
- Contributing guide (opens in new tab)
- No security policy
- No code of conduct
More: languages, topics and project record
Languages
- Python 72%
- JavaScript 19%
- CSS 4%
- HTML 3%
Topics
- autopilot
- boat
- chartplotter
- docker
- fastapi
- fishing
- gps
- machine-learning
- marine
- navigation
- nmea
- offline-first
Project record
- JobOther AI tools
- StatusListed
- Commits415
- Forks33
- Watching17
- Stars in 28 days+3
- CreatedSep 16, 2021
- First seen by usNov 7, 2026
- CheckedNov 7, 2026